Robotics / 2022
ArchivedQuadruped Robot
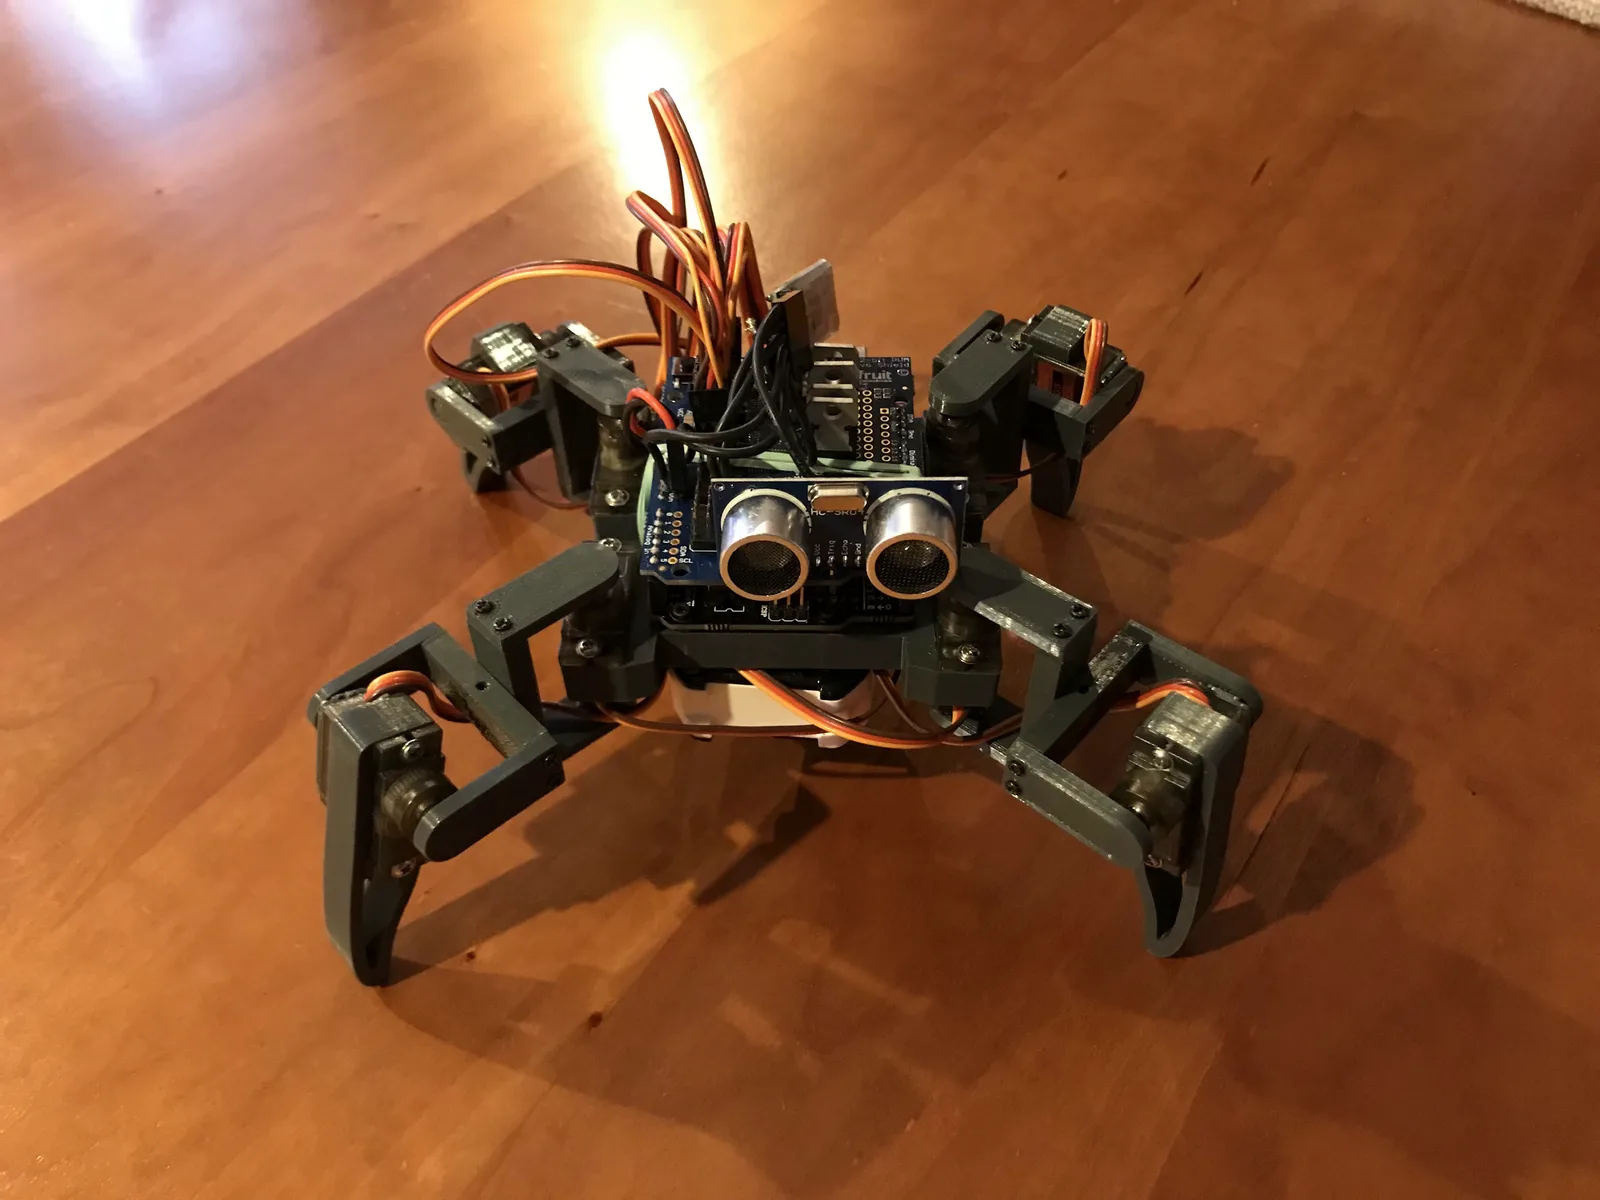
A custom four-legged robot, from Fusion 360 design to C++ control and a mobile controller.
Outcome
Designed, engineered, and built in three weeks.
My role
Mechanical design, construction, and programming
Skills & tools
HardwareC++CAD3D printing
The build
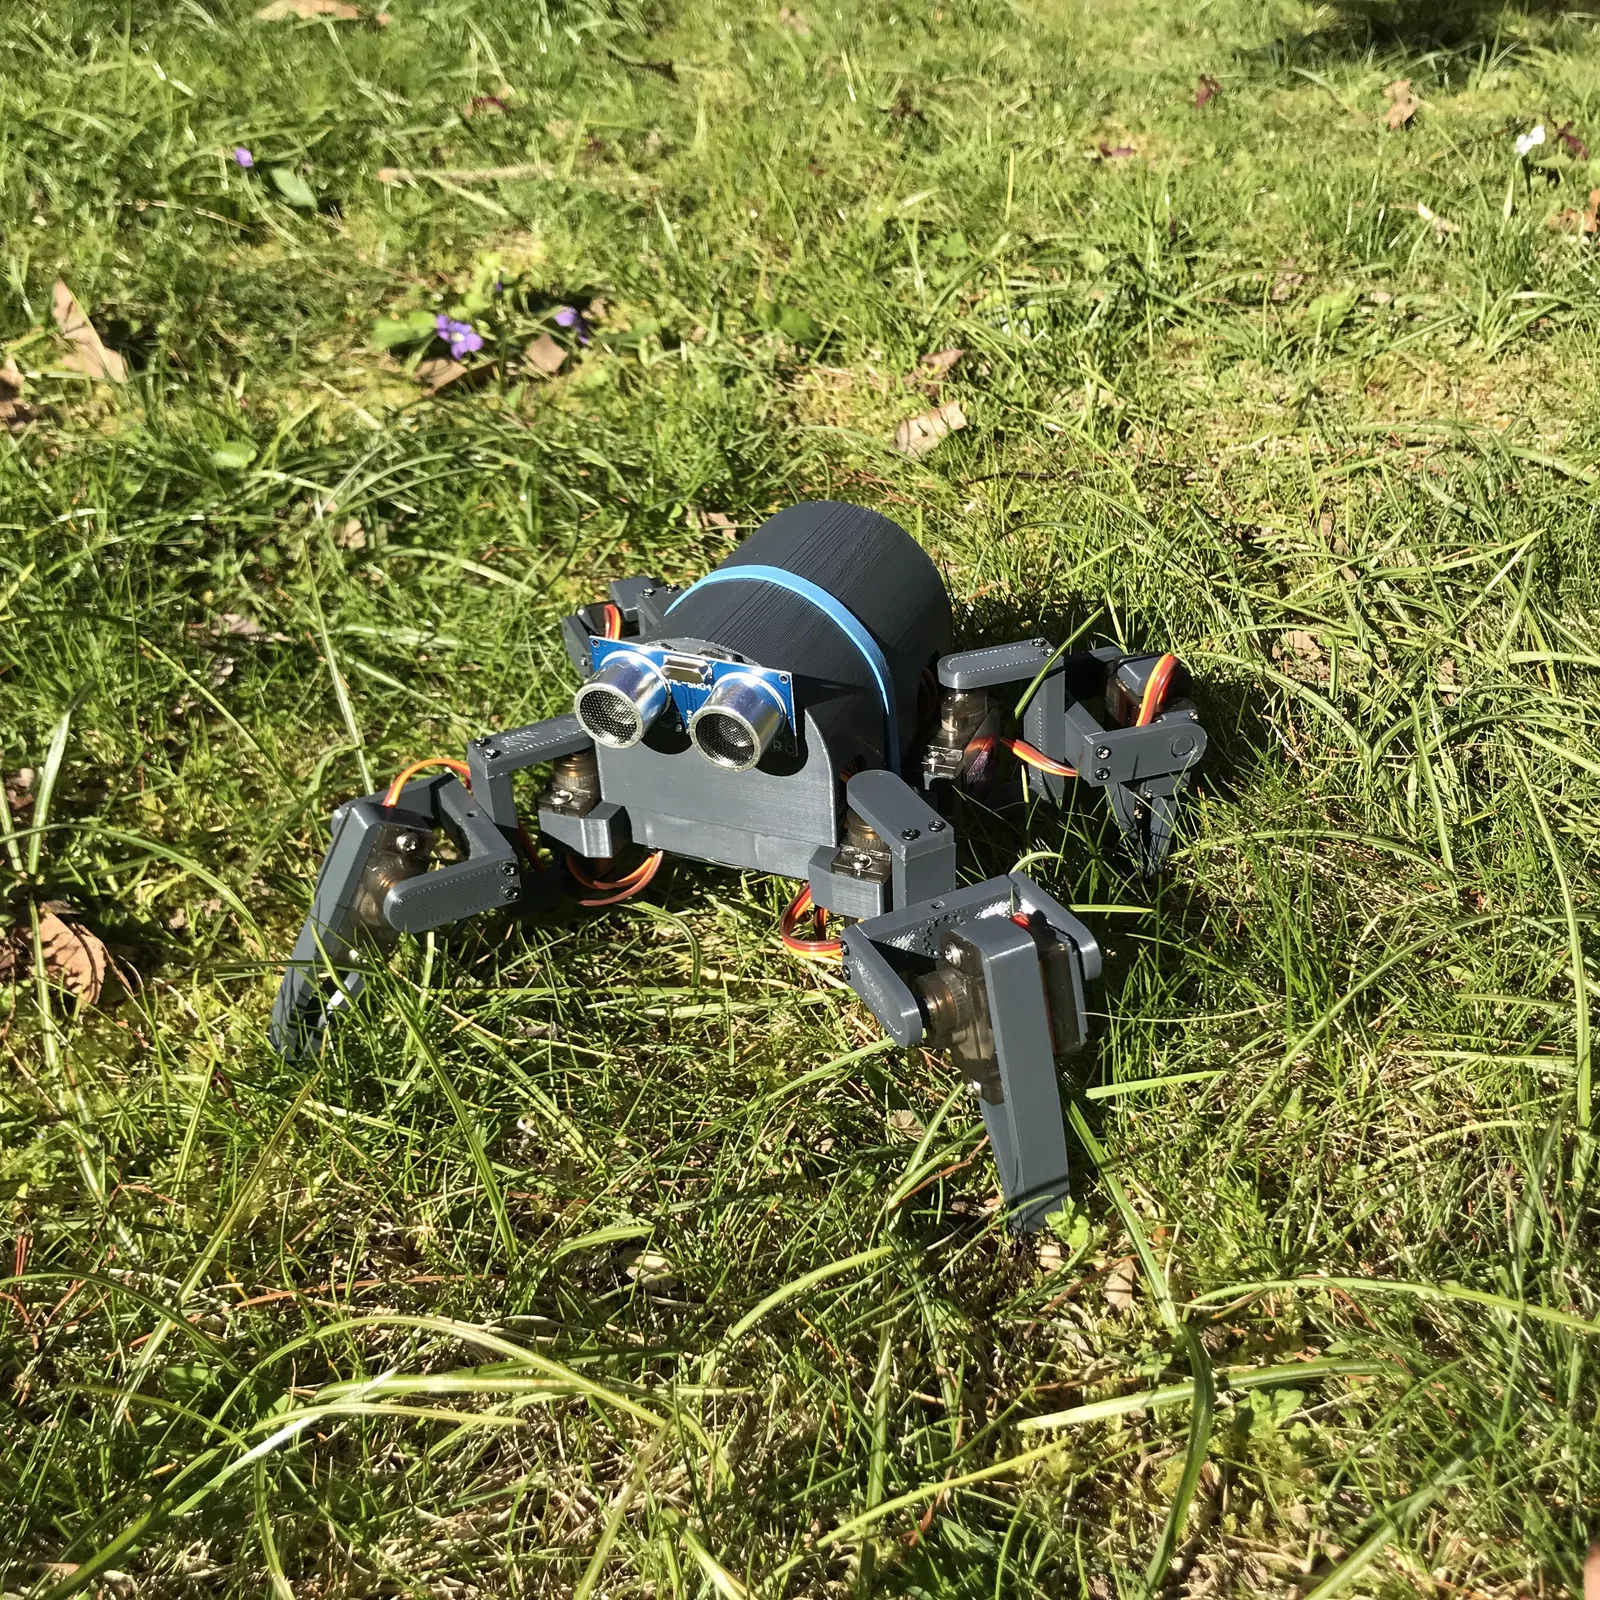
A quadruped robot designed in Fusion 360, engineered, and built in three weeks.
Controls
The robot's program was written in C++. A controller application was developed with MIT App Inventor.
From design to hardware
The project brings together mechanical design, construction, embedded programming, and a separate control interface. The photos and video below document the physical build.
From the build